What Is Axolotl3D?
Axolotl3D, by Anita Hu and Maria Shugrina of NVIDIA's Spatial Intelligence Lab and accepted to ECCV 2026, is a generative model that fuses multi-modal inputs; posed images, visibility masks and partial point clouds; to produce complete 3D geometry, including the parts a sensor never saw. The technical backbone fine-tunes Hunyuan3D-DiT with a unified training strategy that synthesizes diverse conditioning regimes on the fly. See the official project page for details.
The Problem It Solves: Real Scenes Are Always Incomplete
Scan an object with a camera or LiDAR and you only get the surfaces the sensor saw, the back, the underside and occluded regions stay empty. We leave the numbers to the paper itself.
The Robotics Connection: Faithful Physical Simulation
We are not inventing the connection: the project states it: the authors show that completing partially observed objects in captured scenes yields more complete and faithful physical simulation. Since today's mainstream of robot learning is train-in-sim, transfer-to-real, the fidelity of the simulated scene flows directly into policy quality. A half-scanned object means wrong collision geometry in the physics engine; a completed object means contact dynamics close to reality.
What It Means for Unitree Platforms
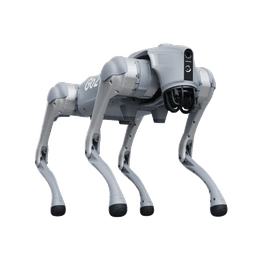
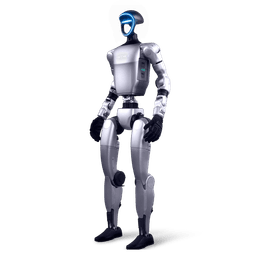
Unitree Go2 and G1 perceive their surroundings with a Livox MID-360 3D LiDAR and an Intel RealSense depth camera, every scan that comes back from the field is, by definition, a partial observation. As the research direction Axolotl3D represents matures, this chain strengthens: build sim-ready digital scenes from the robot's own sensor data → train policies there with unitree_rl_gym or feed world models like UnifoLM-WMA → return to the real robot with fewer surprises. Full disclosure: Axolotl3D has no affiliation with Unitree Robotics; this section is our distributor engineering team's reading.
A Note for Research Teams in Turkey
For university labs building simulation-first robotics, the practical takeaway is this: in hardware selection, sensor data quality (LiDAR + depth) and SDK access are the real investment that keeps doors open to methods like this. That is exactly why Go2 EDU and G1 EDU became the research standard. For procurement via BAP/TÜBİTAK processes, see our institutional buying guide.
Code and Access Status
The work can be followed via the ECCV 2026 publication and the project page. If NVIDIA releases source code, we plan to publish a Turkish documentation translation; license permitting; under the Unitree Türkiye GitHub organization, following the pattern of our unitree_rl_gym and UnifoLM-WMA translations.
Robotlar.org Note
Robotlar.org has no relationship with NVIDIA or the paper's authors, and the paper's numerical results are not reproduced here. Contact us for Unitree platforms, sensor configurations and simulation infrastructure consulting in Turkey; we collect our other research reviews on the open source page.