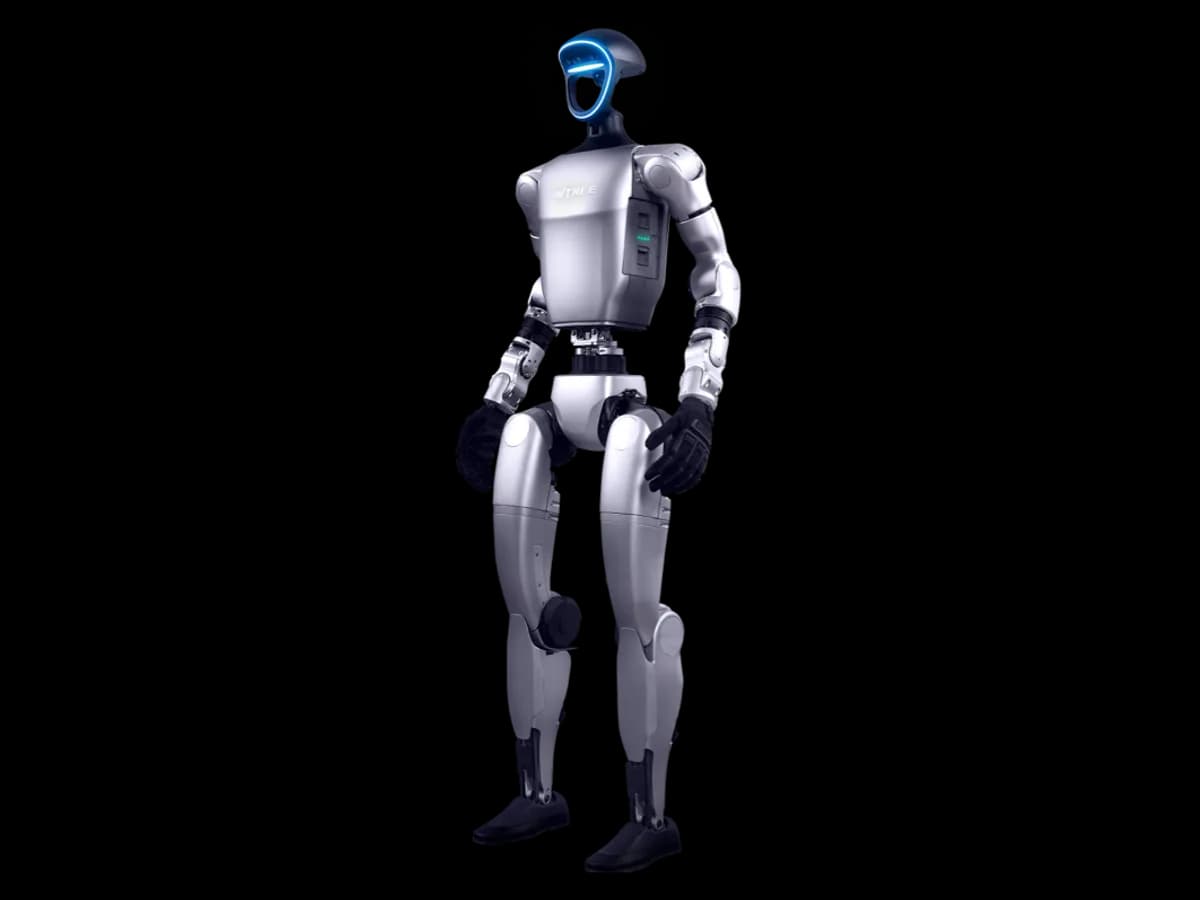
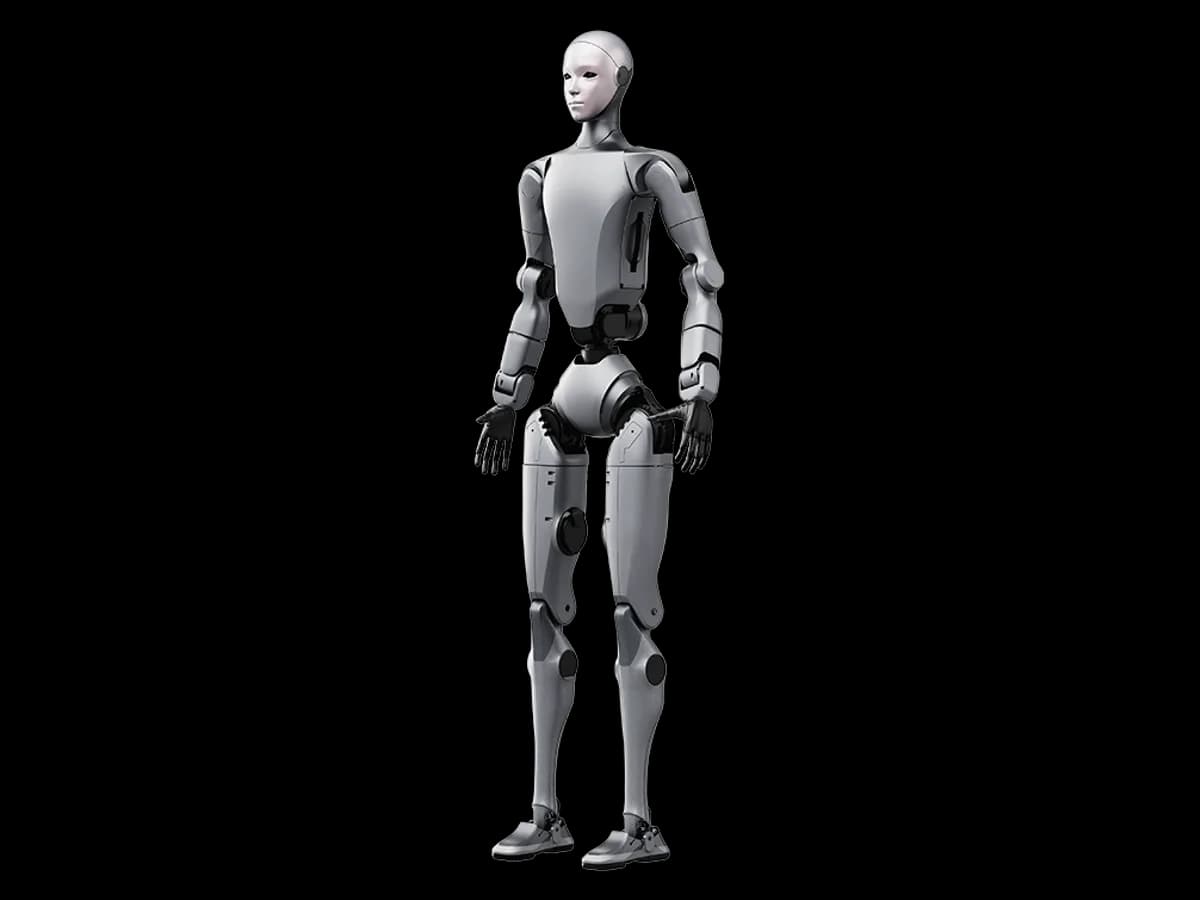
| Degrees of freedom (DoF) | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| TotalExcluding hands; the with-hands figure is noted | 23no handsSource [1][8] | 23 or 29; 43 with two Dex3-1 hands29: with the optional waist and wrist axesSource [1][8] | 26excluding handsSource [31][35] | 26excluding handsSource [31][35] | 31excluding handsSource [46][57] | 31excluding handsSource [46][57] | 23; 29 with 7-DoF armsexcluding hands; 31 in total with grippers, 41 with 6-DoF handsSource [47][61] | 22no hands, no waist jointSource [48][59] | 22no hands, no waist jointSource [48][59] | 22no hands, no waist jointSource [48][59] | 24no handsSource [88][91] | 23no hands, no head jointSource [103] | Conflicting29 joints and 2 grippers (31 actuators)The product page record says 34 active DoF; the 3 head servos in the official wiring diagram are not in the bill of materials.Source [74][79] | 25no handsSource [67] | 31excluding handsThe AimDK 1.0.0 documentation says 30 (neck 1); the store and the model file say 31.Source [69][72] |
|---|
| LegPer leg | 6Source [1][8] | 6Source [1][8] | 6Source [31][35] | 6Source [31][35] | 6Source [46] | 6Source [46] | 6Source [58] | 6Source [59] | 6Source [59] | 6Source [59] | 6Source [91] | 6Source [103] | 6Source [79] | 6Source [69][72] | 6Source [69][72] |
|---|
| Waist | 1 (yaw)Source [1][8] | 1; optionally 3 (yaw, roll, pitch)Source [1][8] | 2 (roll, yaw)Source [31][35] | 2 (roll, yaw)Source [31][35] | 3Source [46] | 3Source [46] | 1 (yaw)Source [58] | NoneSource [59] | NoneSource [59] | NoneSource [59] | 1 (yaw)Source [91] | 1 (yaw)Source [103] | 3 (roll, pitch, yaw)Source [79] | 3Source [69][72] | 3Source [69][72] |
|---|
| ArmPer arm, excluding the hand | 5Source [1][8] | 5; 7 with the optional wristSource [1][8] | 5 (including wrist roll)Source [31][35] | 5 (including wrist roll)Source [31][35] | 7Source [46] | 7Source [46] | 4; 7 in the gripper and hand configurationsSource [47][61] | 4Source [59] | 4Source [59] | 4Source [59] | 5Source [91] | 5 (including wrist yaw)Source [103][110] | 7Source [79] | Could not verify5Value from the product record; it could not be confirmed at the manufacturer source in this check.Source [67] | 7Source [69][72] |
|---|
| HandPer hand, active | None; hand options are on the EDUSource [1] | Dex3-1: 7 active per hand; Inspire: 6 active (12 joints); Dex1-1 gripperOptionSource [1][8] | None; the optional hand is on the R1 EDUSource [31] | Optional dexterous hand: 7 per hand (total rises to 40)OptionThe hand model is not named on the page.Source [31] | Not documentedDepends on the hand option. Official model files include Wuji and Revo2 hand and JZ and YS gripper variants; there is no T2 model file for the Revo 3, Sharpa Wave W01 and Inspire EG2-5CD14-T1 listed in the manual, and the JZ and YS grippers are not in the manual.Source [60][61] | Not documentedDepends on the hand option. Official model files include Wuji and Revo2 hand and JZ and YS gripper variants; there is no T2 model file for the Revo 3, Sharpa Wave W01 and Inspire EG2-5CD14-T1 listed in the manual, and the JZ and YS grippers are not in the manual.Source [60][61] | Gripper (1) or a 6-DoF dexterous handOptionSource [47] | NoneSource [59] | NoneSource [59] | NoneSource [59] | None; the arm ends at the elbow end linkSource [91] | None; the arm ends in a fixed end linkSource [110] | OmniPicker gripper, 1 actuatorSource [76][79] | None; hand and gripper options are on the X2 Ultra onlySource [67] | OmniHand dexterous hand or OmniPicker adaptive gripperOptionThe hand's DoF was not found in this check.Source [67] |
|---|
| Head and neck | None; the depth camera and LiDAR are fixed to the torsoSource [8][9] | None; the depth camera and LiDAR are fixed to the torsoSource [8][9] | 2 (pitch, yaw)Source [31][35] | 2 (pitch, yaw)Source [31][35] | 2Source [46] | 2Source [46] | 2Source [61] | 2Source [59] | 2Source [59] | 2Source [59] | 1 (yaw)Source [91] | NoneSource [103] | Not documentedThe wiring diagram shows 3 head servos; they are not in the open-source bill of materials, which uses a phone as the head display.Source [77][78] | Not documentedThe maker gives no head DoF for the X2. | 2 (yaw, pitch)Source [69][72] |
|---|
| Joints, actuators and torque | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Motor and joint design | Low-inertia, high-speed internal-rotor PMSM. The official training config uses N7520, N5020 and W4010 motorsSource [1][11] | Low-inertia, high-speed internal-rotor PMSM. The official training config uses N7520, N5020 and W4010 motorsSource [1][11] | Low-inertia, high-speed internal-rotor PMSM joint motorsSource [32] | Low-inertia, high-speed internal-rotor PMSM joint motorsSource [32] | Joints with local air coolingThe motor type (internal-rotor PMSM) could not be confirmed in this check.Source [46] | Joints with local air coolingThe motor type (internal-rotor PMSM) could not be confirmed in this check.Source [46] | Not documentedThe dual-encoder note in the manual record could not be confirmed in this check. The official training repository models an E8116 actuator at the knee and an E8112 at hip pitch.Source [63] | Not documentedThe dual-encoder note in the manual record could not be confirmed in this check. | Not documentedThe dual-encoder note in the manual record could not be confirmed in this check. | Not documentedThe dual-encoder note in the manual record could not be confirmed in this check. | Q90 (hip pitch, hip roll, knee) and Q25 (other joints) joint modules; parallel-linkage ankleSource [91][98] | Joint actuators on Ethernet (each joint has its own IP address)The dual-encoder and 70 A peak-current figures in the product record could not be confirmed in this check.Source [103] | PowerFlow R86-3 (hip pitch, hip roll, knee), R86-2 and R52 rotary joints and an L28 linear actuator (wrist); an EtherCAT to CAN FD domain controller (DCU)Source [76][78] | Not documented | Not documented |
|---|
| Knee torqueManufacturer figure; peak and rated stated separately | 90 N·mmaximum, maker's tableSource [2] | 120 N·mmaximum, maker's tableSource [2] | Not documentedThe maker publishes no torque figure. | Not documentedThe maker publishes no torque figure. | Not documentedThe maker publishes no per-joint torque. | Not documentedThe maker publishes no per-joint torque. | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented |
|---|
| Hip torqueManufacturer figure | Not documentedNot on the datasheet. The model file gives hip pitch 88 N·m (rev 1.0) or 139 N·m (newer revisions).Source [9][10] | Not documentedNot on the datasheet. The model file gives hip pitch 88 N·m (rev 1.0) or 139 N·m (newer revisions).Source [9][10] | Not documentedThe maker publishes no torque figure. | Not documentedThe maker publishes no torque figure. | Not documentedThe maker publishes no per-joint torque. | Not documentedThe maker publishes no per-joint torque. | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented |
|---|
| Peak torque, joint not statedCatalogue or module figure; not a knee or hip value | Not documentedThe maker's table gives only the knee torque. | Not documentedThe maker's table gives only the knee torque. | Not documentedThe maker publishes no torque figure. | Not documentedThe maker publishes no torque figure. | 140 N·m peakjoint not statedSource [46] | 140 N·m peakjoint not statedSource [46] | Could not verify130 N·m peakValue from the manual record; it could not be confirmed in this check. Consistent with the 130.5 N·m knee limit in the model file.Source [50] | Conflicting60 N·m peak (manual record)Since 28 August 2026 the official model file limits the knee at 112 N·m (40 N·m before); the deploy configuration still uses 40 N·m.Source [51][59][62] | Conflicting60 N·m peak (manual record)Since 28 August 2026 the official model file limits the knee at 112 N·m (40 N·m before); the deploy configuration still uses 40 N·m.Source [51][59][62] | Conflicting60 N·m peak (manual record)Since 28 August 2026 the official model file limits the knee at 112 N·m (40 N·m before); the deploy configuration still uses 40 N·m.Source [51][59][62] | ConflictingQ90H module 145 N·m peak; Q25H 50 N·m (product record)Official model files limit the Q90 joints at 164 N·m and the Q25 joints at 61 N·m; 145 N·m appears in no repository.Source [85][88] | Conflicting144 N·m peak (product record)The highest joint limit in the official models is 95 N·m (hip pitch and knee); a model limit can sit below the actuator's real peak.Source [101][110] | Could not verifyR86-3: 200 N·m peak, 60 N·m ratedCatalogue value from the product record; not in the repositories. The driver's torque encoding range for the R86 is ±100 N·m.Source [74][78] | 120 N·m peakjoint not statedSource [67] | 120 N·m peakjoint not statedSource [67] |
|---|
| Torque limit in the model fileOfficial URDF/MJCF; knee and hip pitch | Knee 139 N·m; hip pitch 88 N·m (rev 1.0) or 139 N·m (newer revisions)Not the same definition as the datasheet knee torque; one does not replace the other.Source [9][10] | Knee 139 N·m; hip pitch 88 N·m (rev 1.0) or 139 N·m (newer revisions)Not the same definition as the datasheet knee torque; one does not replace the other.Source [9][10] | Knee 60 N·m, hip pitch 60 N·mThe 88/139 N·m values in the MuJoCo model appear copied from the G1; they are not R1 torque.Source [35] | Knee 60 N·m, hip pitch 60 N·mThe 88/139 N·m values in the MuJoCo model appear copied from the G1; they are not R1 torque.Source [35] | Knee 135 N·m, hip pitch 135 N·mSource [57] | Knee 135 N·m, hip pitch 135 N·mSource [57] | Knee 130.5 N·m, hip pitch 98.8 N·mThe December 2025 model file had 60 N·m at the knee; the values changed on 28 August 2026.Source [58] | Knee 112 N·m, hip pitch 68 N·m28 August 2026 model file; the earlier version had 40 and 30 N·m.Source [59] | Knee 112 N·m, hip pitch 68 N·m28 August 2026 model file; the earlier version had 40 and 30 N·m.Source [59] | Knee 112 N·m, hip pitch 68 N·m28 August 2026 model file; the earlier version had 40 and 30 N·m.Source [59] | Knee, hip pitch and hip roll 164 N·m; other joints 61 N·mSource [88] | Knee and hip pitch 95 N·m; hip roll and yaw 54 N·mSource [110] | Knee, hip pitch and hip roll 150 N·m (training URDF)The MuJoCo model has hip roll at 50 N·m.Source [82] | Not documentedNo model file was found for the base X2. | Knee and hip 120 N·mThe new -N version raised the shoulder and ankle torques.Source [72] |
|---|
| Reach and picking from the floor | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Arm length and reach | Not documentedMeasured from the official model file: about 41 cm from the shoulder axis to the palm frame (fingers excluded; not a manufacturer figure).Source [9] | Not documentedMeasured from the official model file: about 41 cm from the shoulder axis to the palm frame (fingers excluded; not a manufacturer figure).Source [9] | Forearm plus upper arm 420 mmSource [31] | Forearm plus upper arm 420 mmSource [31] | Not documented | Not documented | Not documentedThe 45 cm arm length in the manual record could not be confirmed in this check. | Not documented | Not documented | Not documented | Not documentedMeasured from the model file: upper arm 216 mm, forearm 298 mm (no hand; not a manufacturer figure). The product record gives a 1.44 m span with both arms open.Source [88] | Not documentedMeasured from the model file: upper arm 224 mm, forearm 205 mm (no hand; not a manufacturer figure). The product record gives a 1240 mm arm span.Source [110] | Not documentedMeasured from the model file: upper arm 185 mm, forearm 259 mm (gripper excluded; not a manufacturer figure).Source [82] | Not documentedThe 558 mm arm reach in the product record could not be confirmed in this check. | Not documentedThe 558 mm arm reach in the product record could not be confirmed in this check. |
|---|
| Knee and hip range of motionSets the squat limit | ConflictingModel file: knee -5° to 165°, hip pitch -145° to 165°The maker's table values in the product record (knee 0° to 165°, hip pitch ±154°) could not be confirmed in this check and do not match the model file.Source [1][9] | ConflictingModel file: knee -5° to 165°, hip pitch -145° to 165°The maker's table values in the product record (knee 0° to 165°, hip pitch ±154°) could not be confirmed in this check and do not match the model file.Source [1][9] | Knee -10° to 139°; hip pitch -168° to 146°Source [31][35] | Knee -10° to 139°; hip pitch -168° to 146°Source [31][35] | Model file: knee 0° to 148°, hip pitch -168° to 128°Source [57] | Model file: knee 0° to 148°, hip pitch -168° to 128°Source [57] | ConflictingModel file: knee 0° to 122.9°, hip pitch -170° to 125.5°The product manual record gives ±118° for hip pitch; the manual could not be opened in this check.Source [50][58] | Model file: knee 0° to 133°, hip pitch -169.5° to 127.5°The product record also carried the older model file's values (knee 0° to 127°).Source [59] | Model file: knee 0° to 133°, hip pitch -169.5° to 127.5°The product record also carried the older model file's values (knee 0° to 127°).Source [59] | Model file: knee 0° to 133°, hip pitch -169.5° to 127.5°The product record also carried the older model file's values (knee 0° to 127°).Source [59] | ConflictingModel file: knee -20° to 137°, hip pitch -180° to 140°The user manual record gives -30° to 137° for the knee and -29° to 134° for hip roll; the model file has hip roll -25° to 120°.Source [86][88] | Model file: knee -5° to 135°, hip pitch ±150°Source [110] | MuJoCo model: knee 0° to 103°The training URDF uses placeholder limits; physical limits are not stated in the repositories.Source [81] | Not documented | Not documented |
|---|
| Waist motionWaist pitch axis for bending forward | Yaw only, ±150° (model file); no waist pitchSource [8][9] | Yaw ±150°; optional roll and pitch ±30° (model file)Source [1][9] | Yaw ±150°, roll ±30°; no waist pitchSource [31][35] | Yaw ±150°, roll ±30°; no waist pitchSource [31][35] | Model file: pitch -43° to 32°, roll ±20.5°, yaw ±138°Source [57] | Model file: pitch -43° to 32°, roll ±20.5°, yaw ±138°Source [57] | Yaw only, ±58° (model file); no waist pitchSource [58] | No waist jointSource [59] | No waist jointSource [59] | No waist jointSource [59] | Yaw only: -230° to 90° (320° span); no waist pitchSource [88] | Yaw only, ±150°; no waist pitchSource [110] | MuJoCo model: pitch -17° to 90°, roll ±29°, yaw ±180°Source [81] | Not documented | 3-DoF waist (yaw, roll, pitch)Source [72] |
|---|
| Picking from the floorReady feature or development work | Not documentedNo hands and no waist pitch axis; picking from the floor is not documented. | Not documentedThe official API offers squat-to-stand and lie-to-stand transitions; picking objects from the floor is not documented. With the optional waist pitch and a dexterous hand it needs development and load testing.Source [17] | Not documentedNo waist pitch axis; picking from the floor is not documented. | Not documentedNo waist pitch axis; picking from the floor is not documented. | Not documentedIt has a waist pitch axis and 7-DoF arms; picking from the floor is not documented as a ready function. | Not documentedIt has a waist pitch axis and 7-DoF arms; picking from the floor is not documented as a ready function. | Not documentedNo waist pitch axis; picking from the floor is not documented. | Not documentedNo hands, no waist joint and no more than 4 arm axes; picking from the floor is not documented. | Not documentedNo hands, no waist joint and no more than 4 arm axes; picking from the floor is not documented. | Not documentedNo hands, no waist joint and no more than 4 arm axes; picking from the floor is not documented. | Not documentedNo waist pitch axis and no hands; picking from the floor is not documented. | Not documentedNo waist pitch axis and no hands. Firmware 4.1.11 added a walking box-carry arm-clamp motion; no payload figure is given.Source [109] | Not documentedIt has a waist pitch axis and 7-DoF arms; picking from the floor is not documented. | Not documented | Not documented |
|---|
| Perception: cameras, LiDAR, IMU | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Head and body cameras | Depth camera; an Intel RealSense D435i according to the official teleoperation documentationSource [1][9][26] | Depth camera; an Intel RealSense D435i according to the official teleoperation documentationSource [1][9][26] | Binocular camera (monocular on the R1 AIR)Source [31] | Binocular camera (monocular on the R1 AIR)Source [31] | Binocular cameras in the head and waistSource [46][57] | Binocular cameras in the head and waistSource [46][57] | Depth camera (model not stated)Source [47] | Stereo depth camera (model not stated)Source [48] | Stereo depth camera (model not stated)Source [48] | Stereo depth camera (model not stated)Source [48] | Two camera frames, head and torso; the type is not stated in the model fileProduct record: two depth cameras, head and waist, on the Education edition.Source [88] | Could not verifyOptional binocular depth cameraOptionFrom the product record. The model file has a camera frame on the torso; its type and option status are not stated in the repositories.Source [101][110] | Intel RealSense D435 (bill of materials)Source [76] | Interaction RGB camera; touch sensor on the headSource [67] | RGB-D camera, front binocular RGB, rear RGB cameraSource [67] |
|---|
| Wrist camera | Not documented | Not documentedThe official teleoperation documentation lists two RealSense D405 wrist cameras as a do-it-yourself data-collection add-on; not a factory option.Source [26] | Not documented | Not documented | Wrist cameraOptionSource [46] | Wrist cameraOptionSource [46] | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented | Not documented |
|---|
| LiDAR | 3D LiDAR; model files carry a MID-360 mounting frameSource [1][9] | 3D LiDAR; model files carry a MID-360 mounting frameSource [1][9] | Not documentedThe maker's specification table lists no LiDAR; its absence is not stated explicitly. | Not documentedThe maker's specification table lists no LiDAR; its absence is not stated explicitly. | LiDAR (model not stated)OptionSource [46] | LiDAR (model not stated)OptionSource [46] | Not documented | Not documented | Not documented | Not documented | Livox Mid-360 in the navigation configurationOptionThe official navigation repository says it was validated on the real robot; whether it is standard hardware is not stated.Source [89][99] | Not documented | Not in the bill of materialsSource [76] | None; the 3D LiDAR is on the X2 UltraSource [67] | 3D multi-line LiDARSource [67] |
|---|
| IMU | Two IMUs, torso and pelvis (model not stated)Source [9][21] | Two IMUs, torso and pelvis (model not stated)Source [9][21] | IMU in the pelvis (model file)Source [35] | IMU in the pelvis (model file)Source [35] | Yes; the SDK state message carries attitude, gyro and accelerationSource [55] | Yes; the SDK state message carries attitude, gyro and accelerationSource [55] | 9-axis IMUSource [47] | 9-axis IMUSource [48] | 9-axis IMUSource [48] | 9-axis IMUSource [48] | Yes; the ROS 2 interface provides quaternion, acceleration and angular rateSource [95] | USB IMU, 500 Hz by defaultSource [107] | Two YIS320 IMUs (one per DCU)Source [76][78] | Not documented | Not documented |
|---|
| Microphones and speaker | 4-microphone array, 5 W speakerSource [1] | 4-microphone array, 5 W speakerSource [1] | 4-microphone array, speakerSource [31] | 4-microphone array, speakerSource [31] | Microphone array and speakerSource [46] | Microphone array and speakerSource [46] | Circular 6-microphone array and speakerSource [47] | Circular 3-microphone array and speakerSource [48] | Circular 3-microphone array and speakerSource [48] | Circular 3-microphone array and speakerSource [48] | Not documented | Not documented | Not documented | Could not verifyMicrophone array, wireless microphone, speakerValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [67] | Could not verifyMicrophone array, wireless microphone, speakerValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [67] |
|---|
| Processor, GPU and memory | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Control processor | 8-core high-performance CPU (PC1, motion control)Source [1] | 8-core high-performance CPU (PC1, motion control)Source [1] | 8-core high-performance CPUSource [31] | 8-core high-performance CPUSource [31] | Not documentedThe control processor is not stated separately. | Not documentedThe control processor is not stated separately. | Intel i7-1370PWhich configuration includes it could not be confirmed (per the product record, not the base one).Source [47] | Not documented | Not documented | Not documented | Motion-control board (the "nezha" host)Source [96] | Could not verifyIntel Core i7-13700H, 16 GB memory, 512 GB NVMeFrom the product record; the repositories mention only a main control PC.Source [101] | Two Xyber DCU domain controllers (EtherCAT, 1 kHz)Source [78] | Two Rockchip RK3588Source [70] | Two Rockchip RK3588Source [70] |
|---|
| Development computer, GPU and memory | None; the standard G1 does not support secondary developmentSource [3] | PC2: NVIDIA Jetson Orin NX (official repository); the maker says "multiple brands and models, such as Orin"; memory not statedOptionSource [1][28] | Optional NVIDIA Jetson Orin moduleOptionThe maker's page does not say which edition takes it.Source [31] | Optional NVIDIA Jetson Orin moduleOptionThe maker's page does not say which edition takes it.Source [31] | Could not verifyHigh-performance ARM processorValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [46] | NVIDIA Jetson Thor T5000Source [46] | NVIDIA AGX OrinSource [47] | Not documentedThe module name is not published. | Not documentedThe module name is not published. | Not documentedThe module name is not published. | NVIDIA Orin host (application nodes); module variant, memory and TOPS not statedProduct record: Jetson Orin NX 16 GB on the Education edition.Source [96] | Not documentedNo discrete GPU or extra development module is documented. | x86 mini PC (i7-13620H in the bill of materials); a PREEMPT_RT kernel is requiredThe product record's "the compute unit is the user's responsibility" contradicts the official bill of materials.Source [76][78] | None; the Orin NX module is on the X2 UltraSource [67] | NVIDIA Orin NXSource [67][70] |
|---|
| AI computeIn the maker's unit; TOPS and TFLOPS are not compared | No development moduleSource [3] | Not documentedThe maker publishes no TOPS figure for the G1 EDU. 100 TOPS appears only on the G1-D and G1-Comp pages; 157 TOPS was found in no Unitree source.Source [1] | 40 to 100 TOPS (optional Jetson Orin)OptionSource [31] | 40 to 100 TOPS (optional Jetson Orin)OptionSource [31] | Not documentedNo figure is published for the Education edition. | 2070 TFLOPSThe precision (for example FP4) is not stated on the page.Source [46] | 200 TOPSSource [47] | Could not verify48 TOPS (dense)The maker's page offers 48 (dense), 117 and 200 TOPS options. The edition mapping could not be confirmed independently in this check; one summary of the launch announcement says 200 TOPS for the Geek.Source [48][49] | Could not verify117 TOPSThe maker's page offers 48 (dense), 117 and 200 TOPS options. The edition mapping could not be confirmed independently in this check; one summary of the launch announcement says 200 TOPS for the Geek.Source [48][49] | Could not verify200 TOPSThe maker's page offers 48 (dense), 117 and 200 TOPS options. The edition mapping could not be confirmed independently in this check; one summary of the launch announcement says 200 TOPS for the Geek.Source [48][49] | Not documented | Not documented | Not documented | No development moduleSource [67] | 157 TOPS (Orin NX)Source [70] |
|---|
| Battery, runtime and charging | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Battery | 9000 mAh, 13-cell lithium, quick-release smart batterySource [2] | 9000 mAh, 13-cell lithium, quick-release smart batterySource [2] | Quick-release smart battery; the spare pack is 33.12 V, 6000 mAh, 199 WhSource [31][33] | Quick-release smart battery; the spare pack is 33.12 V, 6000 mAh, 199 WhSource [31][33] | 48 V, 10 Ah; magnetic-port chargingNo Wh figure is published.Source [46] | 48 V, 10 Ah; magnetic-port chargingNo Wh figure is published.Source [46] | 10.5 AhVoltage and Wh are not published.Source [47] | 2 AhSource [48] | 5 AhSource [48] | 5 AhSource [48] | Could not verify10,000 mAh, quick-releaseValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [85] | Could not verify475 Wh lithium-ionValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [101] | 48 V 8 Ah lithium-ion (bill of materials)The bill of materials prefers a 12-cell series pack while the kit charger is 13-cell (54.6 V).Source [76] | About 500 WhSource [68] | About 500 WhSource [68] |
|---|
| RuntimeManufacturer figure and test condition | About 2 hourstest condition not statedSource [2] | About 2 hourstest condition not statedSource [2] | About 1 hourcondition not statedSource [31] | About 1 hourcondition not statedSource [31] | 2 hourscontinuous walkingSource [46] | 2 hourscontinuous walkingSource [46] | Up to 2 hours walking, up to 4 hours standingSource [47] | 30 minuteswalking at 0.4 m/sSource [48] | 80 minuteswalking at 0.4 m/sSource [48] | 80 minuteswalking at 0.4 m/sSource [48] | Could not verifyAbout 2 hoursValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [85] | Could not verify2 hoursValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [101] | Could not verify2 hoursValue from the product record; the repositories give no runtime.Source [74] | About 2 hourswalking at 0.5 m/sSource [68] | About 2 hourswalking at 0.5 m/sSource [68] |
|---|
| Charging | 54 V 5 A charger; charge time not statedSource [2] | 54 V 5 A charger; charge time not statedSource [2] | Not documentedCharge time is not published. | Not documentedCharge time is not published. | Not documentedCharge time is not published. | Not documentedCharge time is not published. | Not documentedThe "2 hours or less" in the manual record could not be confirmed in this check. | Not documentedThe "2 hours or less" in the manual record could not be confirmed in this check. | Not documentedThe "2 hours or less" in the manual record could not be confirmed in this check. | Not documentedThe "2 hours or less" in the manual record could not be confirmed in this check. | Could not verify54.6 V 4.5 A; full charge in about 2 hoursValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [86] | Could not verifyAbout 3.5 hours; adapter 46 V 4 AValue from the product record; it could not be confirmed at the manufacturer source in this check.Source [101] | 54.6 V 5 A charger (kit toolkit list)Source [84] | 1.5 hours or lessSource [67] | 1.5 hours or lessSource [67] |
|---|
| ROS 2, SDK and joint-level control | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| SDK and languages | Secondary development not supported (official store)Source [3] | unitree_sdk2 (C++, CycloneDDS; Ubuntu 20.04, aarch64 and x86_64) and unitree_sdk2_python (PyPI: unitree-sdk2)Source [12][18] | No secondary development (R1 EDU only)Source [31] | unitree_sdk2 (locomotion, low-level, arm, audio) and unitree_sdk2_python (since July 2026); an R1 development guideSource [34][36][37] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Booster Robotics SDK: C++ (aarch64 and x86_64, Ubuntu 22.04 and 24.04), Python 1.6.3 (PyPI)Source [52][56] | Native C++ SDK (runs on the robot board after the factory motion service is stopped) and a ROS 2 workspaceSource [92][93] | Fourier-GRX-N1 SDK (.deb): User and PubSub APIs over Zenoh, a Python Developer API; tested on Ubuntu 22.04 with Python 3.11The Ubuntu 20.04 in the product record is outdated.Source [102][105] | AimRT middleware and the DCU driver SDKSource [78][80] | Secondary development interfaces are on the Ultra editionSource [71] | AimDK X2: ROS 2 based, C++ and PythonSource [71] |
|---|
| ROS 2 | Not usable on the robot; secondary development is on the EDUSource [3] | unitree_ros2: Foxy and Humble; G1 low-level, Dex3-1, locomotion, arm-action and audio examplesSource [19] | Not usable on the robot; secondary development is on the R1 EDUSource [31] | No R1-specific ROS 2 example; the shared unitree_hg messages (q, dq, tau, kp, kd) can be usedSource [20] | ROS 2 message package (booster_ros2_interface); the T2 sample stack runs ROS 2 KiltedSource [55][66] | ROS 2 message package (booster_ros2_interface); the T2 sample stack runs ROS 2 KiltedSource [55][66] | ROS 2 message package; the RoboCup demo stack runs ROS 2 HumbleSource [55][65] | ROS 2 message package; the RoboCup demo stack runs ROS 2 Humble and JetPack 6.2Source [55][65] | ROS 2 message package; the RoboCup demo stack runs ROS 2 Humble and JetPack 6.2Source [55][65] | ROS 2 message package; the RoboCup demo stack runs ROS 2 Humble and JetPack 6.2Source [55][65] | ROS 2 Humble (Ubuntu 22.04), Cyclone DDS; the native SDK builds for Humble or JazzySource [92][93] | Not documentedThe SDK uses Zenoh rather than ROS 2; no official ROS 2 package was found.Source [102] | ROS 2 Humble plugin (AimRT)Source [80] | Not usable on the robot; on the Ultra editionSource [71] | ROS 2 (AimDK X2)Source [71] |
|---|
| Joint-level controlPosition, velocity, feed-forward torque, kp/kd | None; requires the EDUSource [3] | LowCmd: q, dq, tau, kp, kd per motor; 500 Hz in the official example; the built-in motion service is released first. Upper-body commands can be blended with walking through arm_sdkSource [13][14][15] | None; requires the R1 EDUSource [31] | LowCmd: 26 motors, q, dq, kp, kd, tau per joint; the motion service is released firstSource [36] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | rt/joint_ctrl: q, dq, tau (feed-forward), kp, kd and weight per motor, in Custom mode. No maximum control rate is published (examples run at 50 to 500 Hz)Source [52][55] | JointCommand: position, velocity, feed-forward torque, torque, stiffness (kp) and damping (kd) per joint, in "joint bridge" mode. The native SDK's motor task runs at 500 HzSource [92][94] | Developer API: current, torque, velocity, position or PD mode per joint; 400 Hz by default, 500 Hz at mostSource [104][105] | /joint_cmd: position, velocity, effort, stiffness and damping per joint; controller 1 kHz, policy 100 HzSource [78][79] | None; on the Ultra editionSource [71] | Low-level motor control for arm, waist and leg joints (AimDK)The command fields (position, velocity, torque, gains) could not be read in detail in this check.Source [71] |
|---|
| Which edition gets development access | G1 EDU only; the standard G1 does not support secondary development. The simulation repositories are publicSource [1][3] | G1 EDU only; the standard G1 does not support secondary development. The simulation repositories are publicSource [1][3] | R1 EDU only (no secondary development on the R1 AIR and R1)Source [31] | R1 EDU only (no secondary development on the R1 AIR and R1)Source [31] | Low-level topics are defined per model for K1, T1 and T2; no edition-level restriction is documented. The SDK has no T2 joint-order constant (booster_deploy t2.py)Source [52][62] | Low-level topics are defined per model for K1, T1 and T2; no edition-level restriction is documented. The SDK has no T2 joint-order constant (booster_deploy t2.py)Source [52][62] | Low-level topics are defined per model for K1, T1 and T2; no edition-level restriction is documentedSource [52] | Secondary development supported (launch announcement); per the SDK the vision detection service is disabled on the GeekSource [49][54] | Per the launch announcement all three editions support secondary development; low-level topics are defined per modelSource [49][52] | Per the launch announcement all three editions support secondary development; low-level topics are defined per modelSource [49][52] | Could not verifyEducation edition; per the product record the Business edition has no secondary developmentThe official repositories publish only "PM01 Edu" and the navigation model; the edition names could not be confirmed in this check.Source [85][87] | Single edition; the SDK installer lists only the N1Source [102] | Single configuration: the open-source kitSource [77] | The X2 Ultra and the X2 EDU announced in 2026; no secondary development on the base X2Source [71][73] | The X2 Ultra and the X2 EDU announced in 2026; no secondary development on the base X2Source [71][73] |
|---|
| Open-source scopeHardware design, software and licence | SDK, ROS 2 package, URDF/MJCF, training, teleoperation and data repositories on GitHub; no hardware design files were foundSource [8][12][25] | SDK, ROS 2 package, URDF/MJCF, training, teleoperation and data repositories on GitHub; no hardware design files were foundSource [8][12][25] | SDK, examples and URDF/MJCF on GitHub; no hardware design files were foundSource [35][36] | SDK, examples and URDF/MJCF on GitHub; no hardware design files were foundSource [35][36] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | SDK, ROS 2 interface, URDF/MJCF, training and deployment repositories on GitHub; no hardware design files were foundSource [52][61][62] | Software repositories are BSD-3-Clause (ROS 2, native SDK, Isaac Lab); the model-file repository has no licence; no hardware design files were foundThe product record's "fully open source" goes beyond this scope.Source [87][93] | URDF and MJCF Apache-2.0, SDK docs MIT, deployment and training repositories LGPL-3.0; the SDK runtime is a closed .deb packageThe product record's "complete hardware package (drawings, bill of materials) published" could not be verified on Fourier's GitHub account.Source [102][110][112] | Hardware (STEP, SolidWorks sources, drawings, bill of materials, assembly instructions), inference software (MulanPSL-2.0) and training code are publishedThe hardware repository has no licence file; the training repository has no LICENSE file.Source [75][80] | URDF and MJCF (MulanPSL-2.0); developer documentation is public; no hardware design files were foundSource [72] | URDF and MJCF (MulanPSL-2.0); developer documentation is public; no hardware design files were foundSource [72] |
|---|
| Simulation | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| URDF / MJCF | URDF and MJCF: 23- and 29-DoF bodies with Dex3-1, Inspire and Dex1-1 variants; the USD model moved to Hugging FaceSource [8][30] | URDF and MJCF: 23- and 29-DoF bodies with Dex3-1, Inspire and Dex1-1 variants; the USD model moved to Hugging FaceSource [8][30] | URDF (R1, R1 AIR) and MJCFSource [35][38] | URDF (R1, R1 AIR) and MJCFSource [35][38] | URDF and MJCF (T2 31 DoF; hand and gripper variants)Source [57][61] | URDF and MJCF (T2 31 DoF; hand and gripper variants)Source [57][61] | URDF and MJCF (T1 23 DoF); a URDF with 7-DoF arms (T1 29 DoF)Source [58][61] | URDF and MJCF (K1 22 DoF)Source [59][61] | URDF and MJCF (K1 22 DoF)Source [59][61] | URDF and MJCF (K1 22 DoF)Source [59][61] | URDF and MJCF (PM01 Edu and the navigation model); USD for Isaac LabSource [88][97] | URDF (Wiki-GRx-URDF) and MJCF (Wiki-GRx-MJCF)The two official model sets disagree on the ankle pitch limit (±45° and ±25°).Source [110][111] | URDF (training) and MJCF (inference)Source [81][82] | Not documentedNo model file was found for the base X2. | URDF and MJCF: X2 Ultra, X2 Ultra -N (OmniHand and OmniPicker variants) and X2 EDUSource [72] |
|---|
| MuJoCo and IsaacOfficial training and deployment repos | MuJoCo (unitree_mujoco, same DDS as the robot), Isaac Gym (unitree_rl_gym), Isaac Lab (unitree_rl_lab, unitree_sim_isaaclab), mjlab (unitree_rl_mjlab)Source [11][21][22][23][24] | MuJoCo (unitree_mujoco, same DDS as the robot), Isaac Gym (unitree_rl_gym), Isaac Lab (unitree_rl_lab, unitree_sim_isaaclab), mjlab (unitree_rl_mjlab)Source [11][21][22][23][24] | MuJoCo (unitree_mujoco; an R1 task and real-robot deploy code in unitree_rl_mjlab); no Isaac Lab or USD asset foundSource [24][38] | MuJoCo (unitree_mujoco; an R1 task and real-robot deploy code in unitree_rl_mjlab); no Isaac Lab or USD asset foundSource [24][38] | MuJoCo sim2sim and real-robot deployment (booster_deploy); no official Isaac task foundSource [62] | MuJoCo sim2sim and real-robot deployment (booster_deploy); no official Isaac task foundSource [62] | Isaac Gym training, MuJoCo and Webots testing, real-robot deployment (booster_gym); MuJoCo sim2sim (booster_deploy)Source [62][64] | Isaac Lab 2.2 motion-imitation tasks (booster_train), MuJoCo sim2sim and deployment (booster_deploy), RoboCup demoSource [62][63][65] | Isaac Lab 2.2 motion-imitation tasks (booster_train), MuJoCo sim2sim and deployment (booster_deploy), RoboCup demoSource [62][63][65] | Isaac Lab 2.2 motion-imitation tasks (booster_train), MuJoCo sim2sim and deployment (booster_deploy), RoboCup demoSource [62][63][65] | MuJoCo (ROS 2 workspace and native SDK), Isaac Lab 2.3.2 and Isaac Sim 5.1.0 (engineai_rl_lab), Gazebo (navigation)Source [93][97][99] | Isaac Gym training (Wiki-GRx-Gym), MuJoCo sim2sim (Wiki-GRx-Mujoco), Isaac Lab configuration (fourier_lab)Source [112][113][114] | Isaac Gym Preview 4 training, MuJoCo sim2simSource [80] | Not documented | MuJoCo models; no official training repository was foundSource [72] |
|---|
| Supply in Turkey, warranty and quote | G1 (Basic) | G1 EDU | R1 | R1 EDU | T2 Education | T2 Professional | T1 | K1 Geek | K1 Education | K1 Professional | PM01 Edu | N1 | X1 | X2 | X2 Ultra |
|---|
| Supply and service in Turkey | Stock, warranty, installation and service: Robotlar.org (Unitree distributor in Turkey)Source [139] | Stock, warranty, installation and service: Robotlar.org (Unitree distributor in Turkey)Source [139] | Stock, warranty, installation and service: Robotlar.org (Unitree distributor in Turkey)Source [139] | Stock, warranty, installation and service: Robotlar.org (Unitree distributor in Turkey)Source [139] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteLatest firmware: 4.2.2 preview (16 December 2025).Source [109][140] | Project-based supply: import, delivery and commissioning itemised in the quoteThe product ships as a kit of parts. The repositories have not been updated since April 2025; current sales status could not be verified in this check.Source [77][140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] | Project-based supply: import, delivery and commissioning itemised in the quoteSource [140] |
|---|
| Manufacturer warranty | 8 monthsSource [1] | 18 monthsSource [1] | 8 monthsSource [31] | 12 monthsSource [31] | Not documentedThe T2 warranty period was not found in this check. | Not documentedThe T2 warranty period was not found in this check. | 1 yearSource [47] | 3 monthsSource [48] | 1 yearSource [48] | 1 yearSource [48] | Not documented | Not documented | Not documented | 8 months of maintenance serviceThe maker says "maintenance service"; warranty terms are not written separately.Source [67] | 18 months of maintenance serviceThe maker says "maintenance service"; warranty terms are not written separately.Source [67] |
|---|
| Price and quote status | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] | By quote; no list price is publishedSource [141] |
|---|