Unitree dexterous hand
Unitree Dex5-S
Announced by Unitree on 21 September 2026, the Dex5-S is a five-finger hand module at exact human-hand size. All 22 active degrees of freedom are backdrivable and every joint carries impact torque protection. Everyday objects such as scissors, a spoon or a drink can are handled as they were designed for the human hand.
- 22
- active degrees of freedom
- 1:1
- real human-hand size
- 620 g
- weight
- 43 sn
- official launch video
Unitree Robotics official launch video, 21 September 2026. Footage at real speed.
Technical summary
Technical specifications.
- Degrees of freedom
- 22 active joints: thumb 5, index, middle and ring 4 each, little finger 5.
- Size and weight
- Exact human-hand size (1:1); the manufacturer's table gives 102 x 187 x 26 mm and 620 g. Tools and objects designed for people are used without any change of scale.
- Joint behaviour
- All 22 motors are direct drive, backdrivable and fitted with dual encoders: a joint yields to external force instead of resisting it, which is the basis for force control.
- Load
- Peak 2 kg, continuous 1 kg per hand.
- Interface and supply
- 2 x T1s Ethernet, high-speed RS-485 and USB; 1000 Hz control (Ethernet and USB). 15 to 65 V, 200 W peak.
- Protection
- Impact protection structure on 22 joints; per the official video, impact torque limiting on every joint.
- Versions
- Dex5-S and the tactile Dex5-S Pro; the mechanical values are the same, and the Pro's tactile point count is not published.
Values from the specification table on Unitree's Dex5-S product page (13 November 2026) and the official launch of 21 September 2026. Fingertip force, speed, repeatability and an official list of compatible robots are not published.
Full specification table and Dex5-S Pro version comparisonTasks shown in the video
Objects made for people, handled like a human hand.
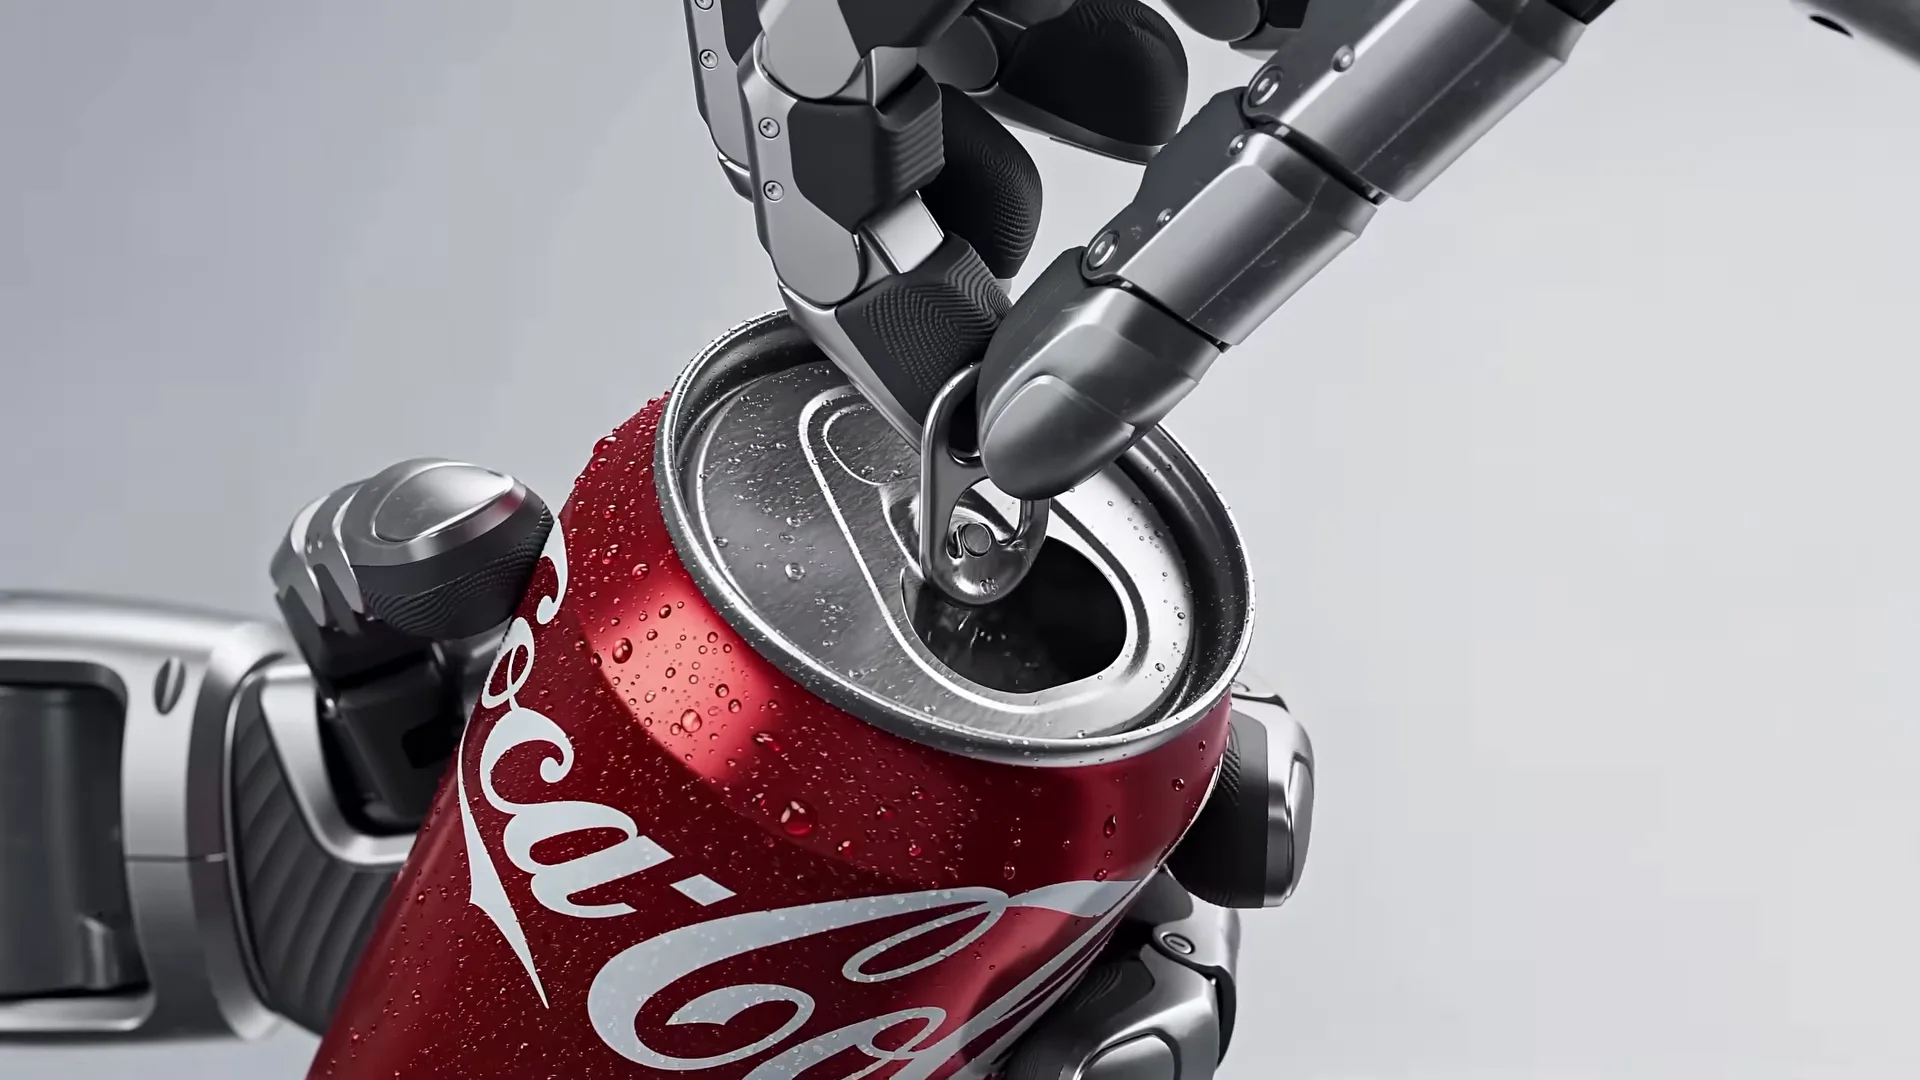
Opens a drink can's pull tab with a single finger.
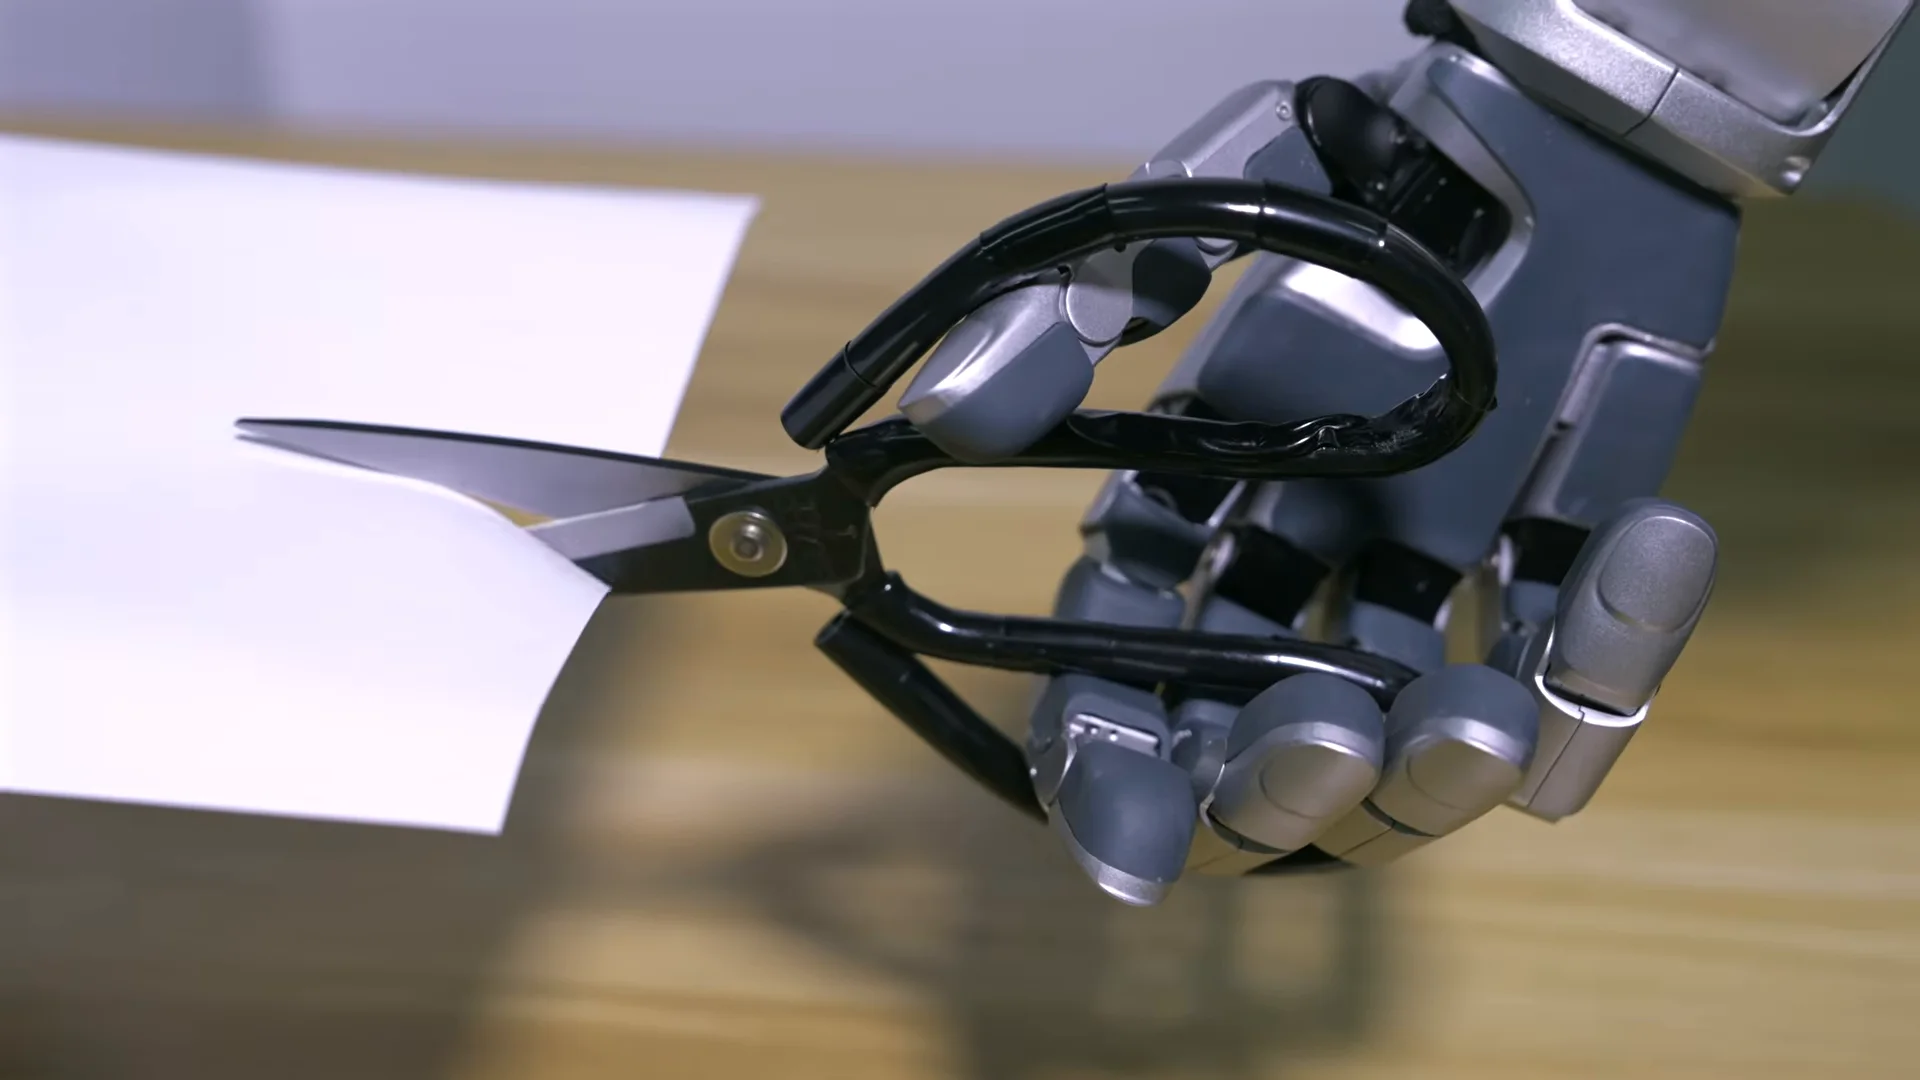
Holds scissors with a human grip and cuts paper.
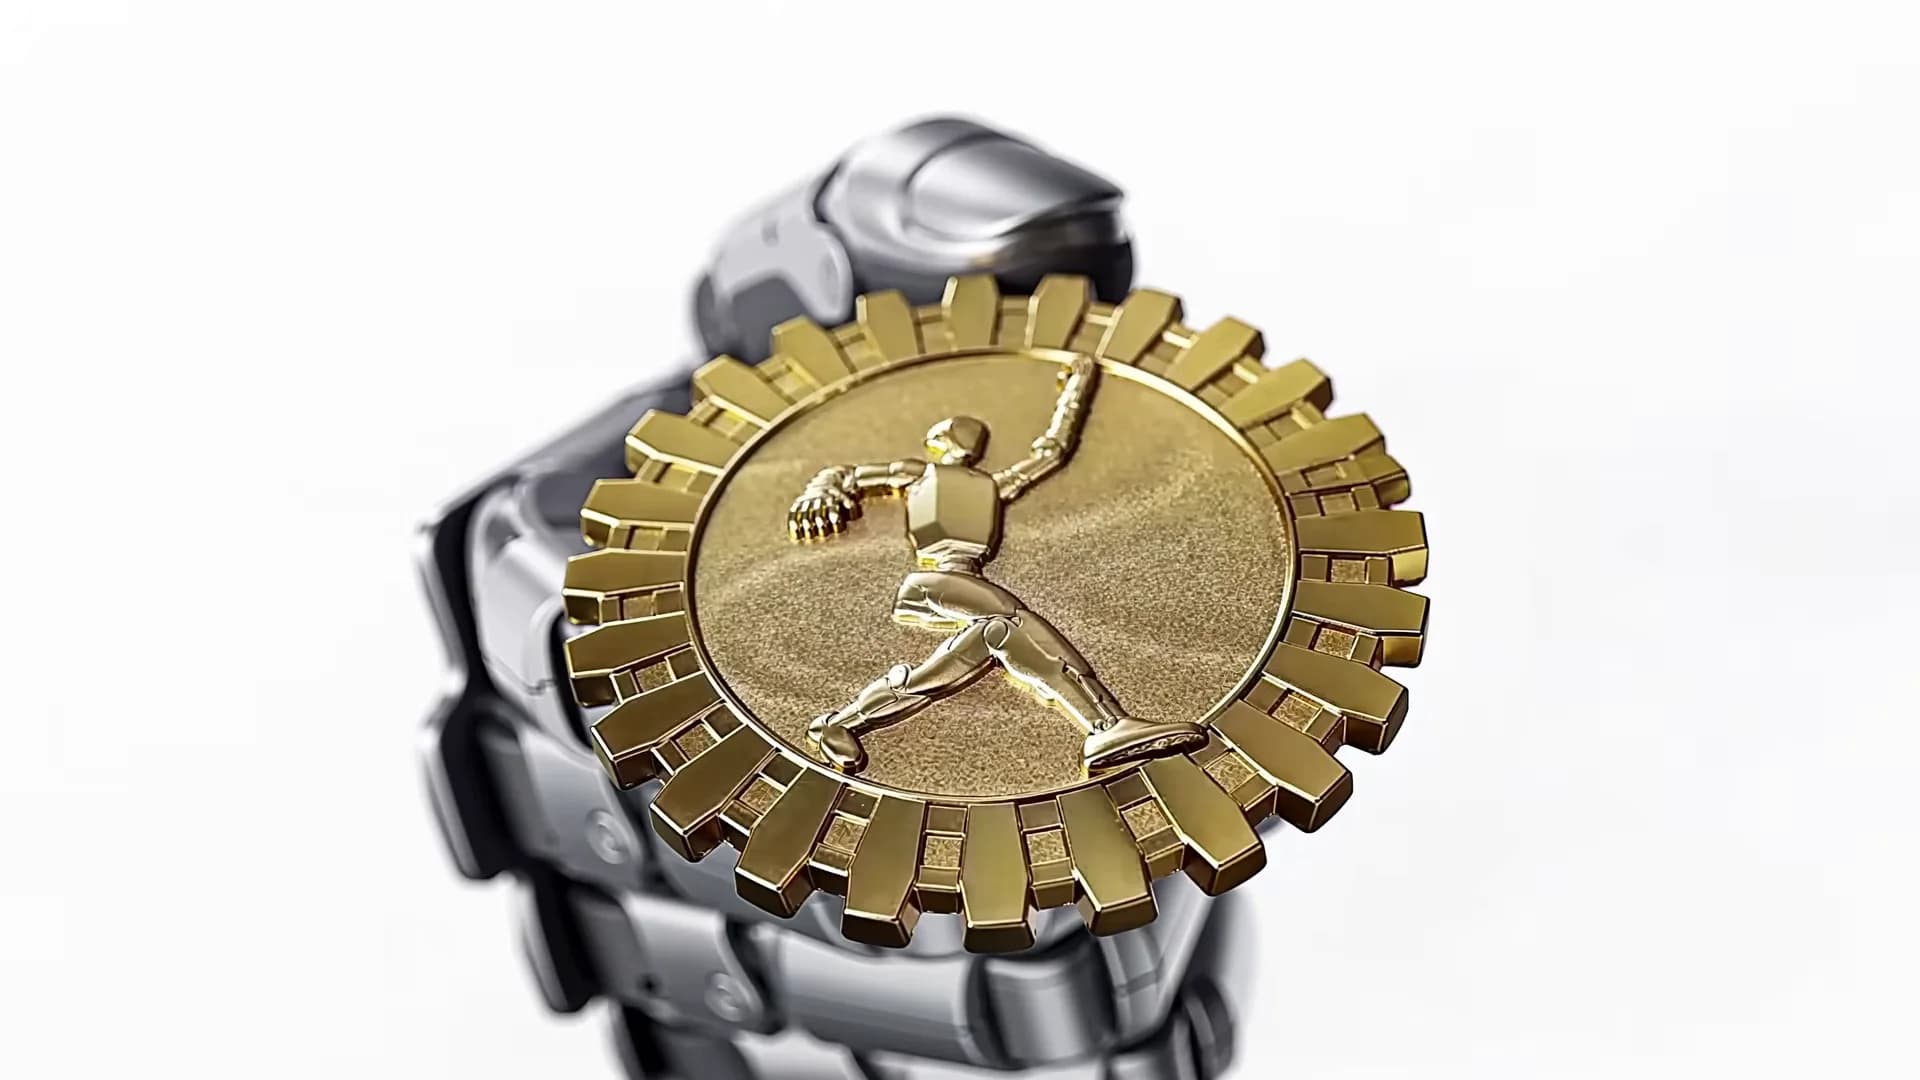
Carries a thin, flat object on its fingertips.
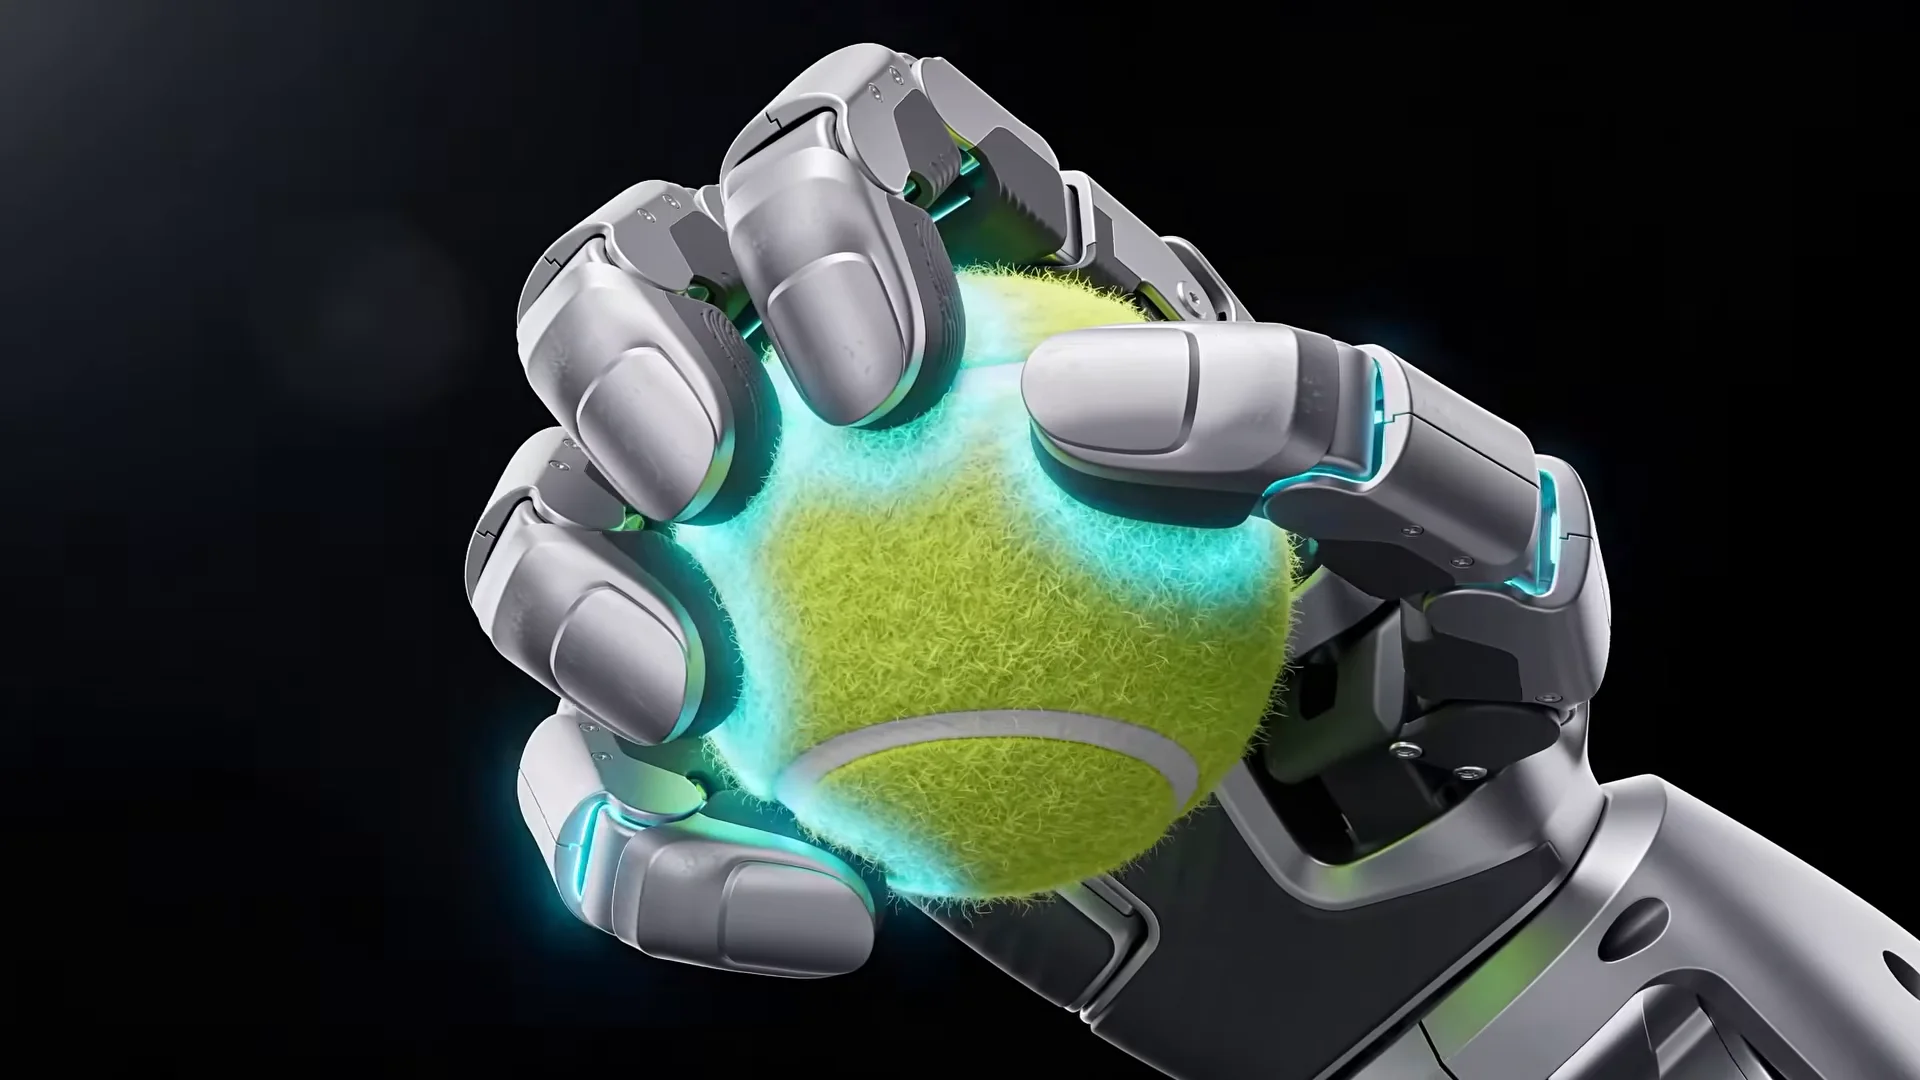
Wraps all five fingers around a tennis ball.
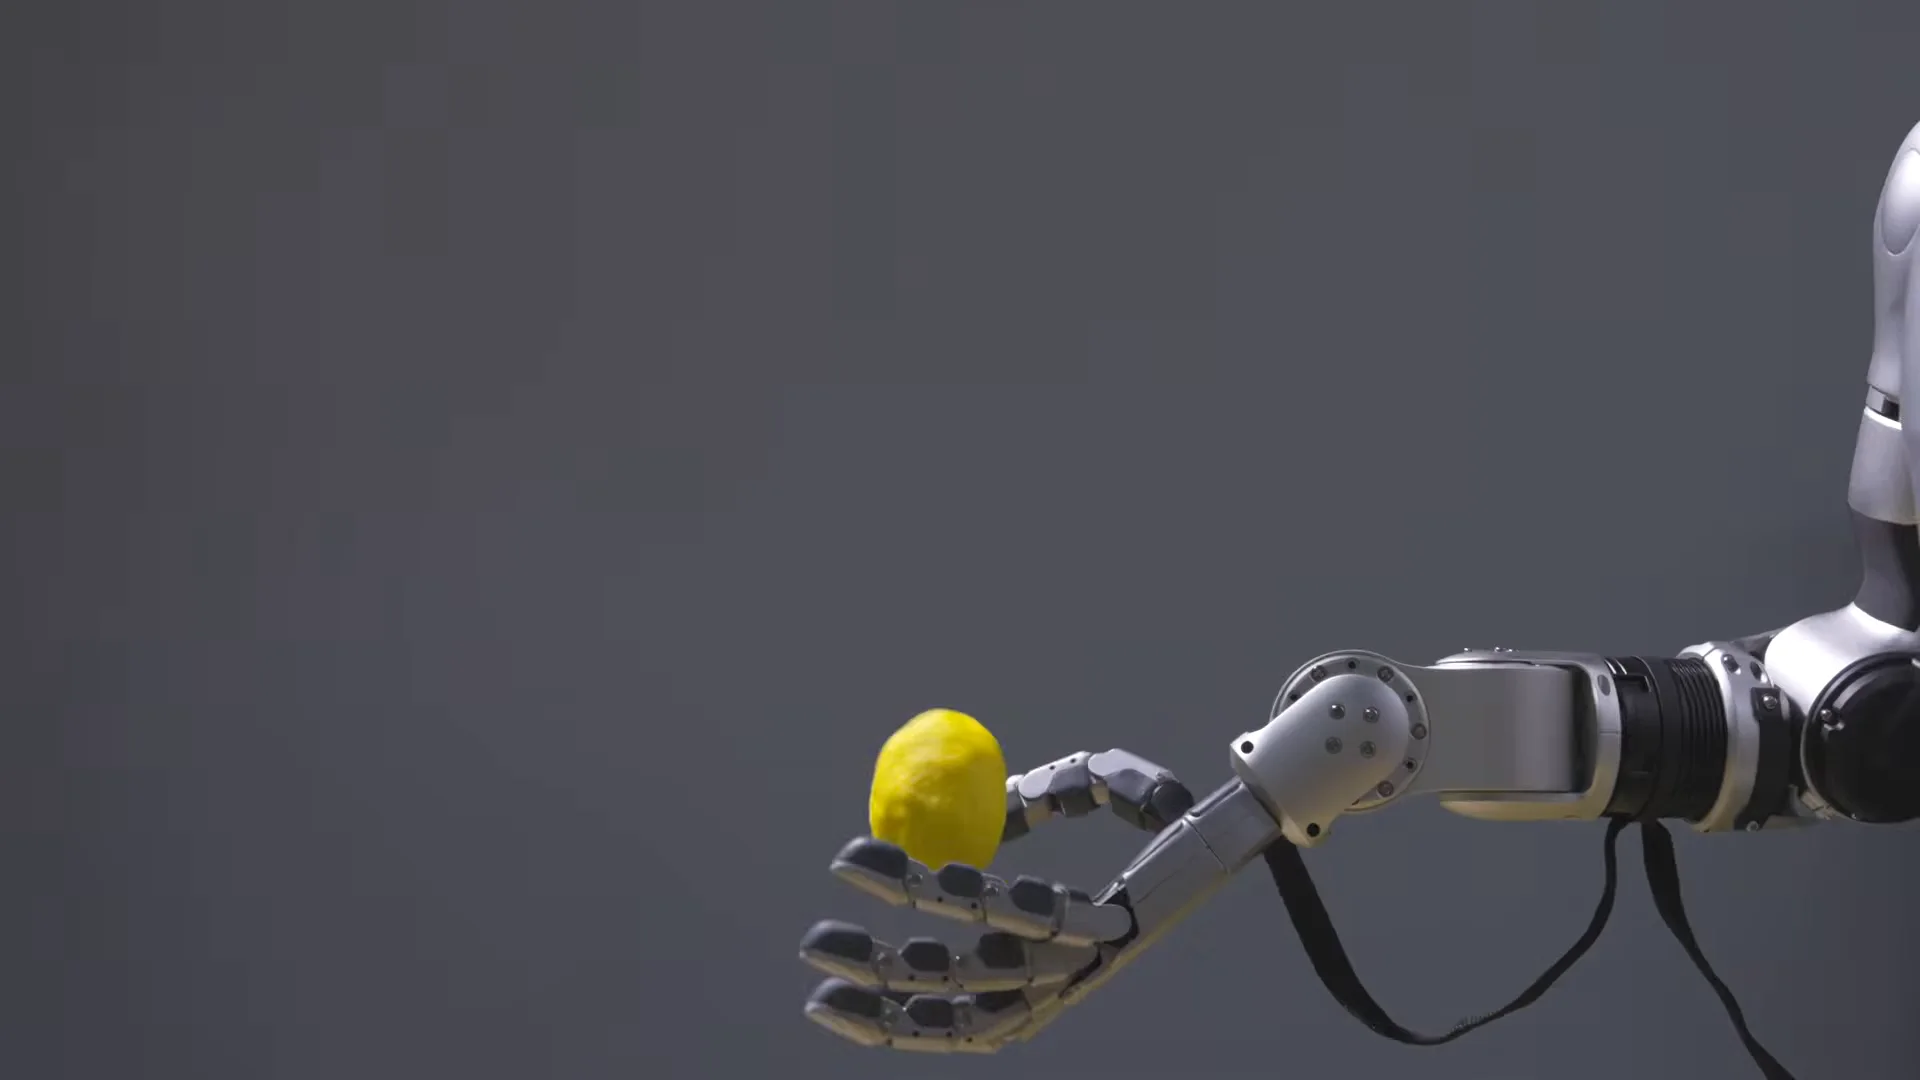
Mounted on a humanoid arm, holding a small piece of fruit.
Images: Unitree Robotics official launch, 21 September 2026.
Why it matters
Three design decisions, and what they mean in the field.
Backdrivable joints
The motor can be turned by an external force. When the hand bumps into an object, or an object slips during a grasp, the joint yields instead of resisting. Contact force is read from motor current, and grasps become soft and compliant.
Impact torque protection
During a sudden impact the torque a joint transmits is limited, so gears and motors are protected from overload. For a hand in constant contact with everyday objects this is the basis of durability.
Exact human-hand size
Scissors, spoons, keys and cans made for people are used as they are. In teleoperation and imitation learning, the human hand's motion transfers to the robot without any change of scale.
The Unitree hand family
Where the Dex5-S sits in the family.
| Model | Fingers | Degrees of freedom | Highlights |
|---|---|---|---|
| Dex1-1 | Gripper, two jaws | Single-axis grasp, 90 mm stroke | Grip force adjustable from 5 to 120 N; 550 g; compatible with G1, H2 and R1. |
| Dex3-1 | 3 | 7 (thumb 3, index 2, middle 2) | 33 pressure sensors, hybrid force and position control; 710 g; compatible with G1. |
| Dex5-1 | 5 | 20 (16 active, 4 passive) | ±1 mm fingertip repeatability; 94 tactile points on the Dex5-1P version; 1,100 g. |
| Dex5-S | 5 | 22 active | Exact human-hand size; 22 direct-drive, backdrivable joints; 620 g; 2 kg peak load; tactile Pro version. |
Source: Unitree Robotics official product information.
Where it is used
From research to data collection.
Humanoid robot R&D
Two-handed manipulation and grasping research on full-size humanoid platforms.
Teleoperation and data collection
The operator's hand motion transfers to the robot at one-to-one scale; demonstration data is collected for imitation learning.
Model training
Demonstrations collected with human-scale objects feed vision-language-action model training directly.
Everyday-object tasks
Finger-level tasks on objects made for people: cans, scissors, spoons and keys.
Corporate quotation
Let us plan the quotation and delivery for the Dex5-S.
Robotlar.org is the Official Distributor of Unitree Robotics in Turkey; Dex5-S supply, the choice of a compatible humanoid platform and integration support are handled from one source.
Robotic system costs are optimised according to the selected hardware platform, additional sensor and payload configurations, and the integration scenarios specific to your site. Share your requirements and our engineering team will prepare a feasibility report and a pro forma quotation tailored to your organisation.
- Supply and delivery scheduling backed directly by the manufacturer
- Site- and mission-focused technical feasibility and simulation
- Turnkey hardware, software and mission integration
- Advisory on corporate tenders, specifications and administrative processes
Direct contact and advisory line: 0850 532 6 777
Frequently asked
What is the difference between the Dex5-S and the Dex5-1?
The Dex5-1 is a 1,100 g hand offering 20 degrees of freedom across five fingers (16 active, 4 passive). The Dex5-S is designed at exact human-hand size with 22 active degrees of freedom; all joints are backdrivable and every joint carries impact torque protection. The model that suits your project is selected together with our engineering team, based on your application requirements.
Which robots is it compatible with?
With its exact human-hand size, the Dex5-S is a hand module intended for full-size humanoid platforms and is shown on a full-size humanoid arm in the official launch. The hand configuration, mounting interface and software integration for your platform are defined by our engineering team within the project scope and stated in writing in the quotation.
Does it have tactile sensing?
The standard Dex5-S has no tactile sensing; the Dex5-S Pro version adds it. The manufacturer has not published the Pro's tactile point count. Within the Unitree hand family, tactile sensing is also offered with 33 pressure sensors on the Dex3-1 and 94 tactile points on the Dex5-1P.
How much does the Dex5-S weigh and how big is it?
According to Unitree's specification table the Dex5-S weighs 620 g and its size is given as 102 x 187 x 26 mm. The peak load per hand is 2 kg and the continuous load 1 kg. The full specification table is on the Dex5-S product page.
Why does backdrivability matter?
In a backdrivable joint the motor can be turned by an external force. When the hand bumps into an object or the object slips, the joint yields instead of resisting; force control and safe contact rest on this property. On the Dex5-S all 22 joints work this way.
How are price and delivery determined?
The price is set by the chosen version and configuration; we do not publish list prices for Unitree products. When you share your requirements, our engineering team prepares a pro forma quotation and a delivery schedule for your organisation; as the Official Distributor of Unitree Robotics in Turkey, Robotlar.org handles supply and integration support from one source.
Compare dexterous robot hands.
Unitree Dex5-S, Dex5-1, Dex3-1, Dex2/5 and the Dex1-1 gripper, in one table with Wuji and BrainCo hands.